Showing posts with label Joe White. Show all posts

Thursday, March 17, 2011

Failure (Almost) to Launch

Today we launched the AUV in Pembroke. It took a couple trips in Timmy's smaller car to get the AUV, and all 10 of us out to the coast. We were all excited to get in the water (Chris was the most enthusiastic), and had planned ahead by wearing our swimsuits. We were especially excited about the AUV's first launch in the Mediterranean. Our plan was to take the AUV out to about 10 meters from the water line, just past the big rocks. We would then let it go out on its first mission to a waypoint approximately 100 meters off of shore. It was then supposed to turn around, and come back to a final stopping point of 60 meters off shore. This was mostly what happened.


Our first problems started when we had trouble transferring files for the mission from the toughbook to the AUV's hard drive. We were finally able to get them transferred after many debugging attempts, resets, and reboots. It was at this point that we were ABANDONED by Chris, as he had to go off to give a talk at the University of Malta (which he reportedly rocked). Next, we had trouble with the IVER (AUV) connecting to its instruments. This was solved by another reboot of the IVER. We finally had success! Time to launch that robot.


Tyler and Jeff got into the water and Andy, Billy, and Brig brought the IVER to the water's edge. I had a nice view from up on a large rock where we had placed the Wifi box. Tyler and Jeff swam the IVER out and the rest went according to our initial plan. BUT THEN! IT STOPPED! So, it turns out, we over estimated the distance from the coast, and when the IVER came to rest it was too far to establish a Wifi connection so we could not manually drive the IVER back. As the IVER started drifting away in the current, we realized we needed to send a rescue mission. Since Tyler and Jeff were already in the water, they were sent to go after it. It was very exciting watching them bring the IVER back, especially when the waves started getting bigger. In the end, we successfully launched and completed a mission - even though it wasn't quite what we had expected. Hooray for success!


Zoe showed the initiative and went for a quick swim and then we all followed suit (except Billy and Andy).


Too bad Timmy wasn't around for the rescue mission, he could have used his super reach to pick it up right out of the middle of the sea!

Friday, March 4, 2011

Late Night Repairs

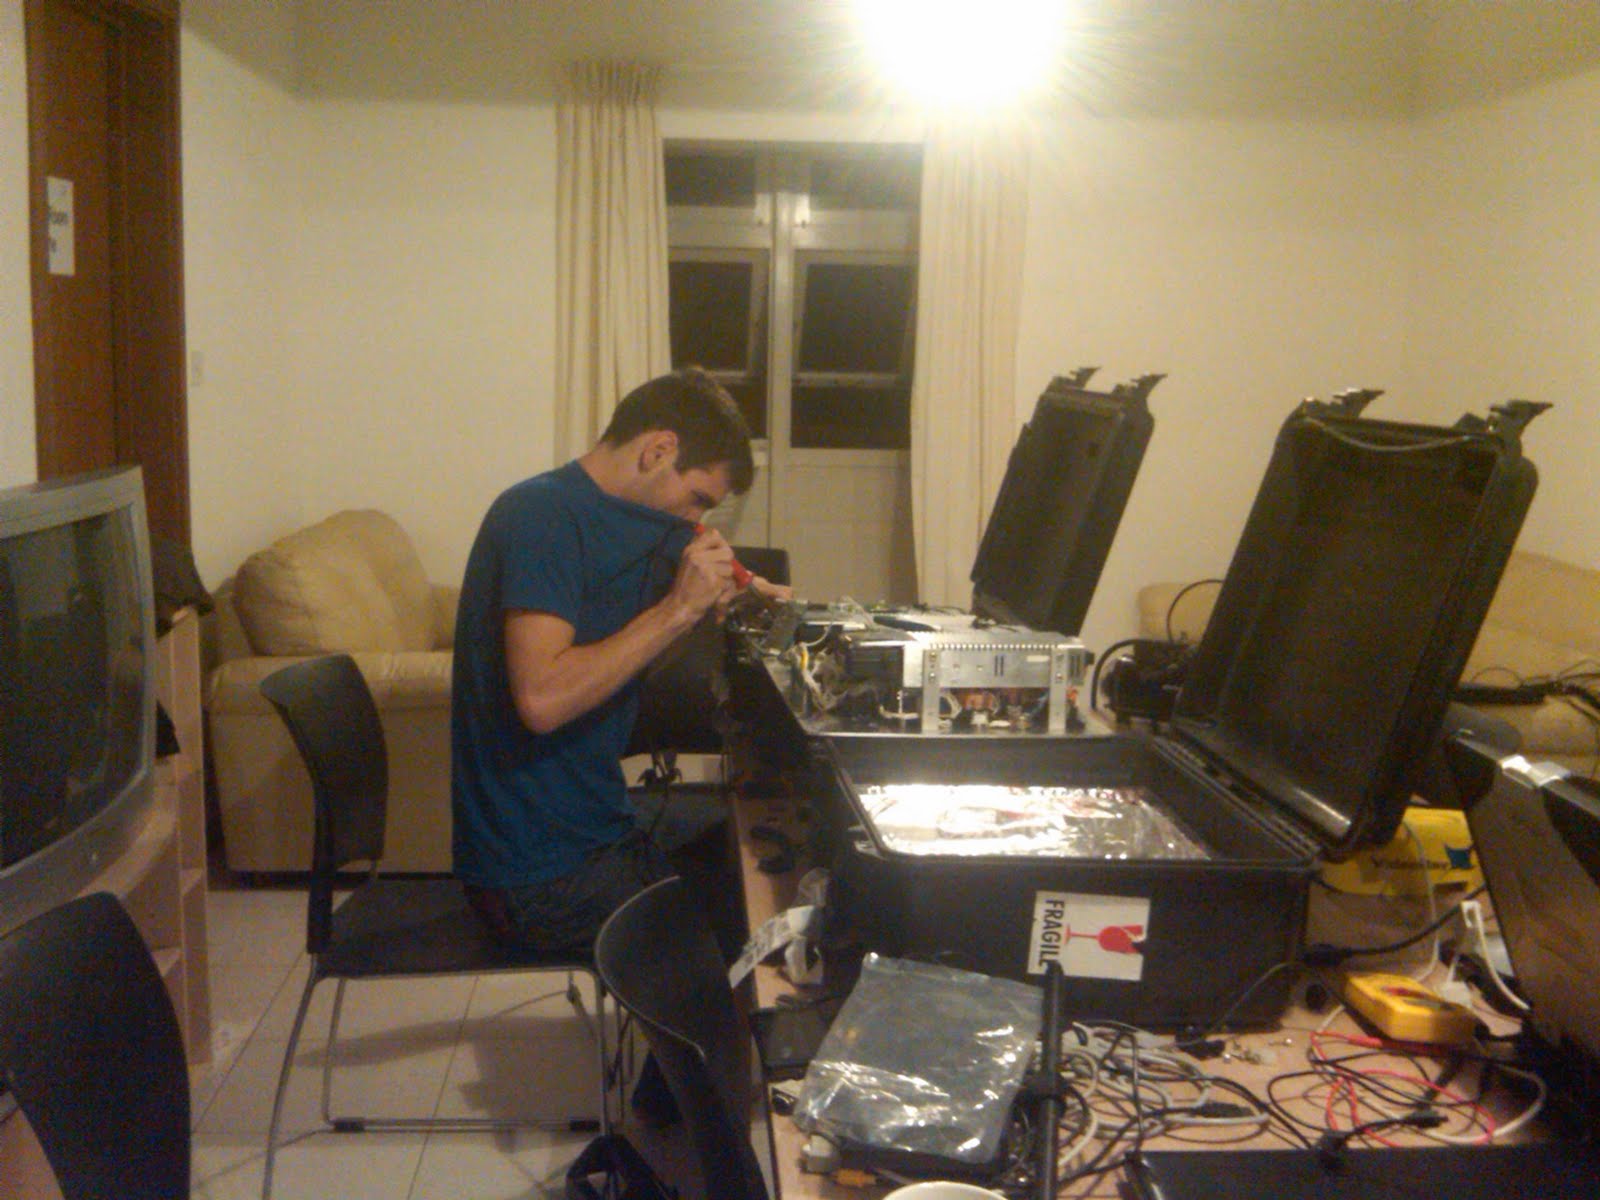
When we arrived in Malta on Monday, the LCD in one of the control boxes for the VideoRay was broken. (It was working before we left). Since we have two control boxes, we managed to use the working control box with the VideoRay to continue exploring wells and cisterns. On Wednesday night, it was time to start analyzing the data to verify whether or not it was valid. Only after about 15 minutes, it became apparent through a sanity check that most of the depth measurements were invalid. (The invalid data sets had a depth of -17 meters). After discussing this with Joe and Chris, Joe emailed VideoRay about the problem. They responded within the hour suggesting we disassemble the control box and analyze it for loose connection or faulty components if we were brave enough.

Immediately, I brought out the tools and began tearing it down. During this breakdown process, Joe, Jane, and I began brainstorming about what the problem could possibly be. I decided to start with fixing the LCD screen on the broken control box in order to check if that control box was recording a depth of -17 meters. I began switching out components from the broken control box with the equivalent components in the working control box to consolidate the problem. After ruling out the LCD screen itself and the removable Atmel microcontroller, I melted off the epoxy on the PCB connectors of the LCD control board with a soldering iron and found that switching the LCD control board out with the other control boxes LCD control board solved the problem. When switching these boards, both of the control boxes began to function properly (as far as the LCD screen goes). After discussing this with Joe and Jane, we concluded that the problem must have been from the epoxied connectors since the both of the LCD screens worked after switching them out.


It was about 5am, Malta time, when we reassembled the boxes and calibrated the compasses for the next day. We then logged data using both of the control boxes separately with the VideoRay out of water and found that the depth reading was about 1 meter. We decided this value was better than -17 meters and we only needed to calibrate the depth sensor, which could be done in the morning. This was about the time we called it a night.

Locations of Site Visitors